Big Daddy
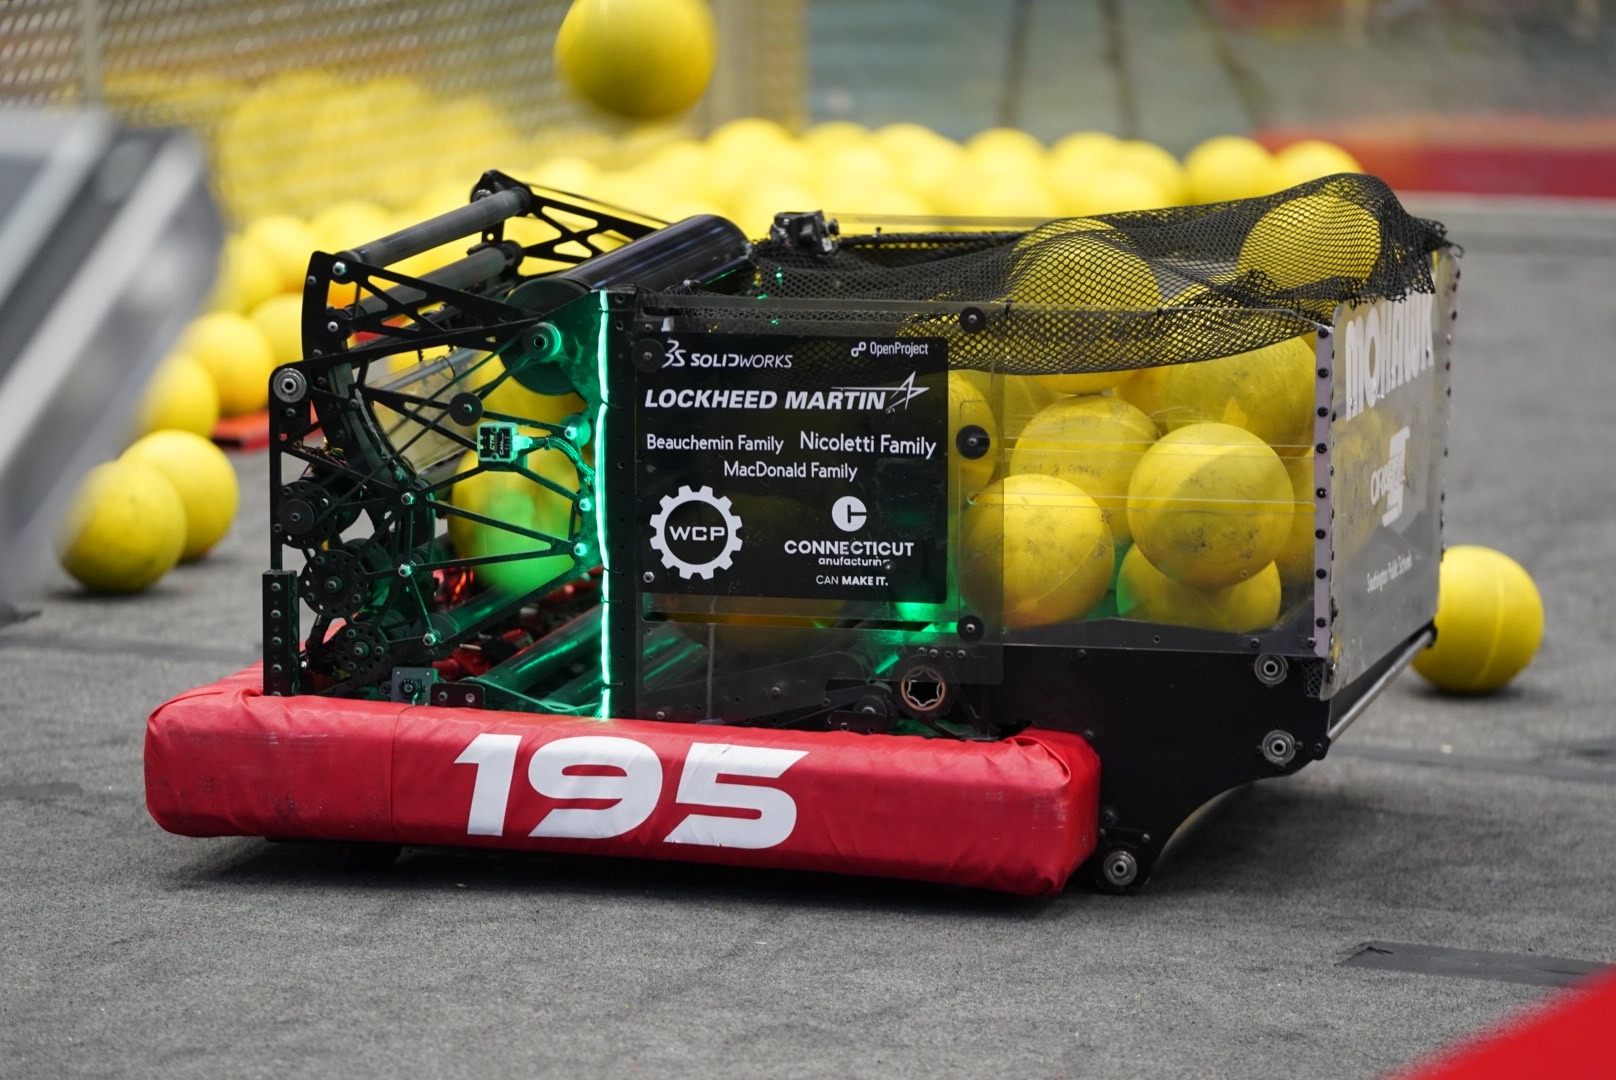
Big Daddy is the name of our robot for the 2026 FRC season game, Rebuilt, where the goal is to shoot yellow balls called fuel into a hub while it is active. During this season, I led the software team, helped teach the underclassmen, and stayed in the pit to fix emergency errors.
Some of my favorite things I developed for this season were a virtual field and robot to test autonomous routines in, unique logic for automatically aiming towards the goal and shooting at a power determined through a map we tuned over 5 times throughout the season, auto paths, and a dashboard that displays whether the robot is allowed to shoot in the hub. My favorite part, though, is the shoot on the move logic. I was able to implement time of flight recursion using Newton's method to allow the robot to shoot accurately while moving. The Desmos graph below visualizes the logic.
During this season, I learned a lot. I improved in both Python and C++, I learned how to implement new code using existing ROS infrastructure, and I learned how to troubleshoot more effectively. However, my most important takeaways were from leadership. I learned that good leaders should have clear communication, so I ran a weekly announcement to all of the programming kids to let them know when to show up and what is happening on the team. Overall, the season was a lot of fun and a big learning experience, and I am excited to make more robots in the future. For more information, watch me explain the robot at the Watch Interview link below.